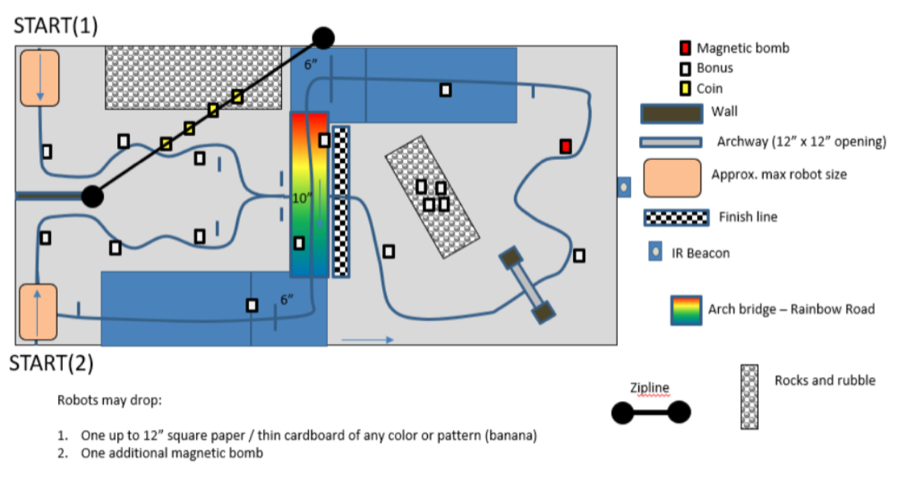
A from-scratch autonomous robot built for a 6-week instrument design course: navigate a Mario Kart-themed course, complete laps, dodge obstacles, and go head-to-head against an opposing robot within a 2-minute time limit. The approach was to stay light and agile and take every shortcut the course allowed, which meant a sub-1.5kg chassis that could still take repeated impacts.
Mechanical
Modelled, machined, and tested every mechanical component in-house.
Rack-and-pinion servo steering, plus a front bumper to knock away obstacles and absorb impact.
Electronics
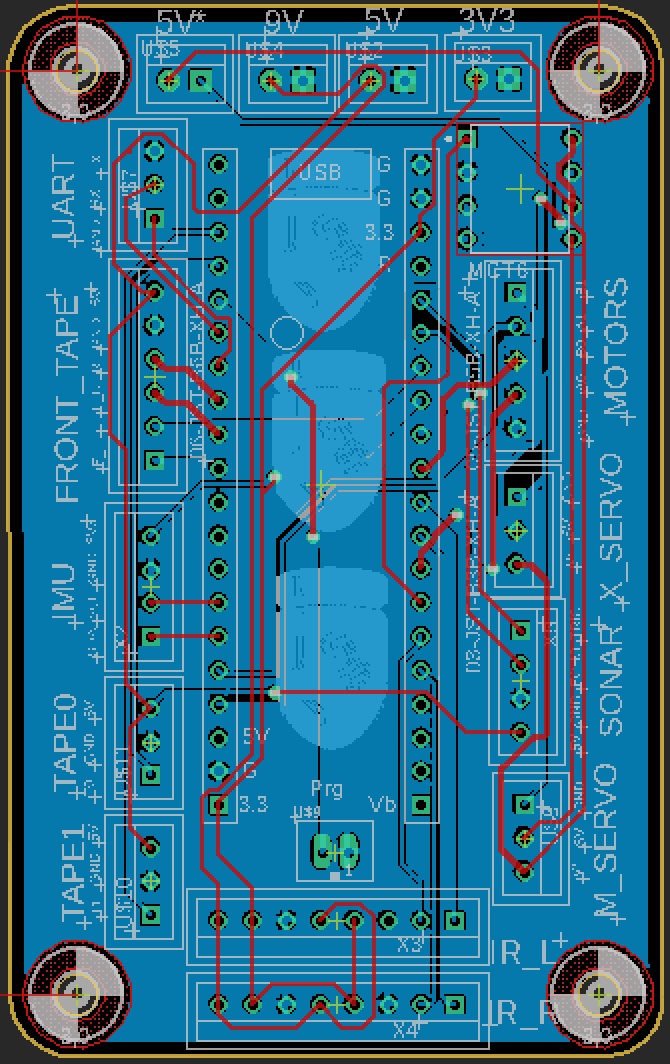
Custom PCBs for tape/IR sensing, H-bridge motor control, and power management, all interfacing with an STM32.
Optocoupled signals into the H-bridge and servos to keep noise out of the control loop.