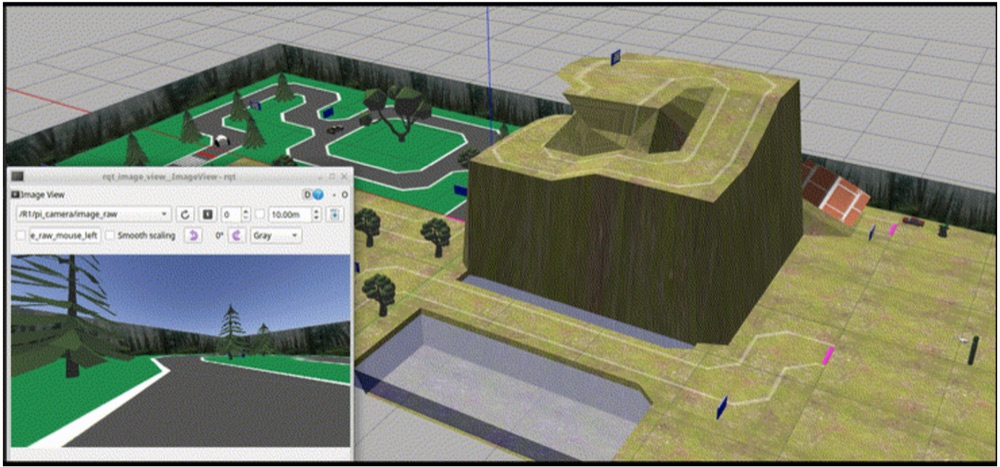
An end-to-end imitation-learning driving stack for a simulated ROS/Gazebo competition: navigate rough terrain, dodge obstacles, and read roadside “clueboards” to solve a mystery. Placed 1st out of 17 teams, and the only imitation-learning entry to complete a full run.
Driving
Recorded thousands of frames of camera feed paired with joystick input during manual driving to build a training set.
Trained several model architectures on that data, with OpenCV background subtraction and masking layered on top to catch obstacles and NPCs.
A finite-state machine in ROS ties perception to driving behavior.
Clue detection
Homography and perspective transforms align the clueboards and letter cutouts regardless of viewing angle.
Generated a mixed dataset of synthetic (blurred/cut) and recorded letters, then trained a CNN for classification.